Norbert Frank Mba · Enugu, Nigeria

Code meets
the physical
world.

Robotics & UAV systems engineer. I work across mechanical design, electronics, and intelligent software to bring machines to life.

FIELD NOTES / 001ROBOTIC MANIPULATION
Motion, by design.Five-axis arm · Planetary actuation
CONCEPT DRAWING
01 / ROBOTICS02 / UAV SYSTEMS03 / EMBEDDED ELECTRONICS04 / SOFTWARE

Selected engineering work

Built to move.
Designed to learn.

Prototypes, integration work, and research at Wicrypt Labs, alongside my personal FPV build.

Prototype · Wicrypt Labs

Black Mamba

Control-surface actuation for an MQ-9-inspired fixed-wing prototype, translating stick inputs into servo movement.

Aircraft controlsMG90 servosBrushless propulsion
Engineering notes +
  • Configured MG90 servos for manual control-surface actuation.
  • Integrated a DXW D3536 1200KV brushless motor and 90 A ESC for propulsion.
  • Focused on direct manual control; no telemetry or autonomous-flight claim.
In development · Wicrypt Labs

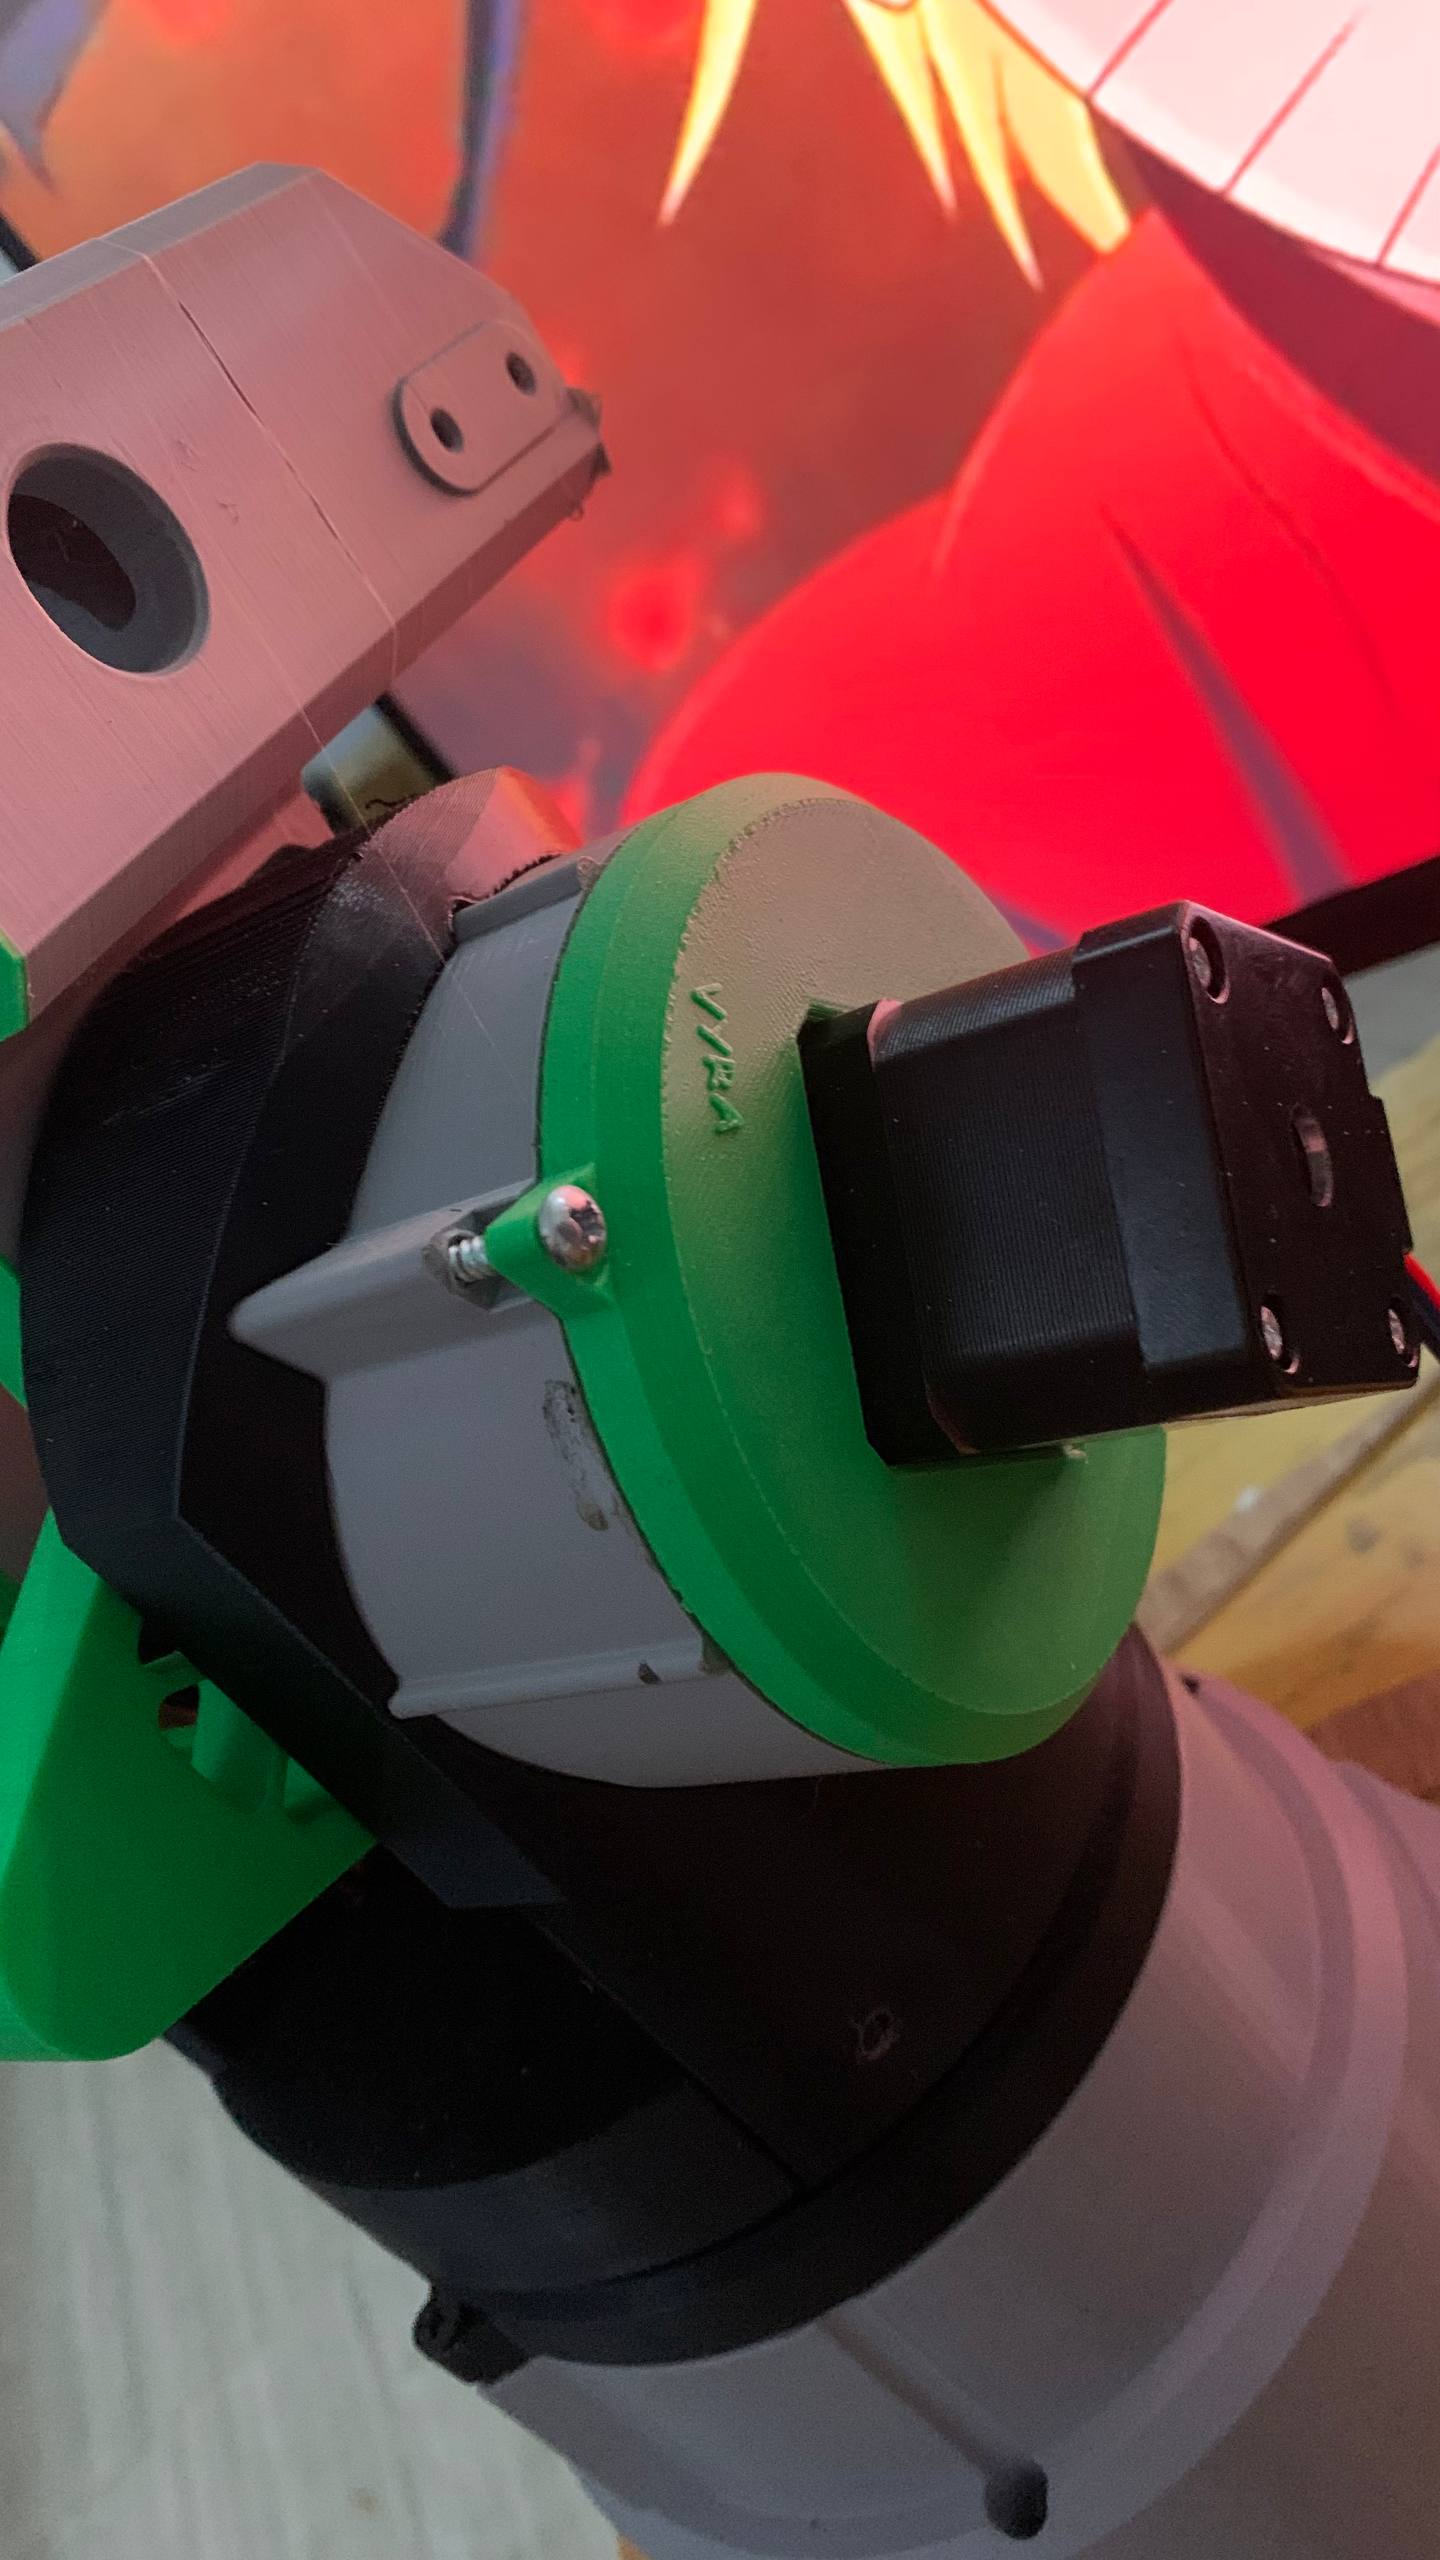
Five-axis robotic arm

Team development of a stepper-actuated arm with interchangeable five-finger hand and gripper tooling.

FreeCADInventorPlanetary gearing
Engineering notes +
  • Modelled planetary gearing: an 8:1 base reduction and a two-stage 64:1 reduction for the load-bearing joint.
  • Designed around 1.8 N·m and 3 N·m steppers, with servo actuation on the remaining three axes.
  • A 10 kg payload at 1 m is a design target, pending physical validation.

Prototype · Wicrypt Labs

Two-axis gun turret prototype

Mechanical design and electronics work on a two-axis turret prototype, from gear systems and joints to CAD modelling and simulation.

FreeCADInventorKiCadMotion control
Engineering notes +
  • Designed and modelled the mechanical assembly in FreeCAD and Autodesk Inventor, including gearing and joints.
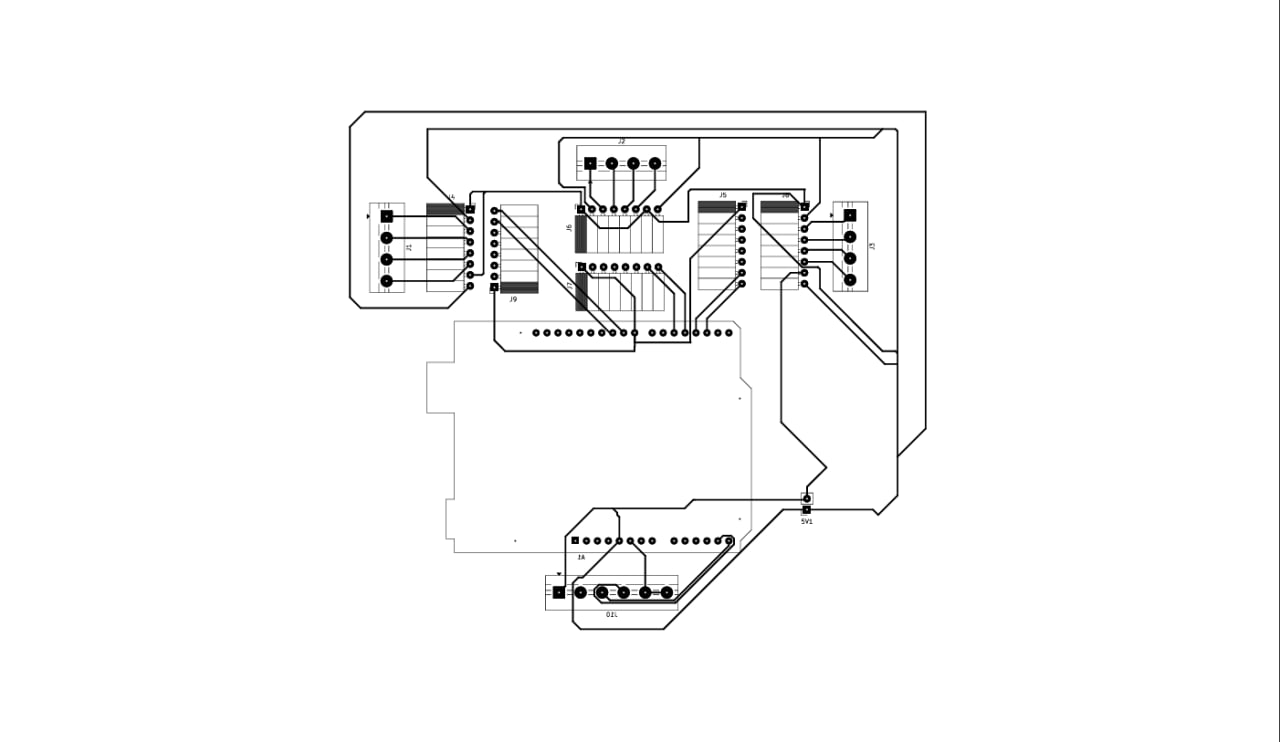
  • Designed a KiCad PCB integrating TMC2209 stepper drivers, a 16-channel servo controller, and Arduino command handling.
  • Explored simulation and visualisation as part of prototype development.

PCB design · Wicrypt Labs

Embedded motion control

An integrated control-board design for a two-axis electromechanical prototype supporting industrial robot-arm exploration for metal arc 3D printing.

KiCadTMC2209ArduinoComputer vision
Engineering notes +
  • Designed the PCB in KiCad with TMC2209 stepper drivers, a 16-channel servo controller, and Arduino command handling.
  • Explored distributed image capture with Raspberry Pi Zero and Jetson Orin Nano, using OpenCV and YOLOv8.
  • Mechanical CAD work also includes a two-axis turret prototype; contributions cover gearing, joints, electronics, and simulation.
05 / Simulation & learningILLUSTRATION

Research · Wicrypt Labs

From simulation to motion

Exploring robot-arm motion, visualisation, and reinforcement learning as a foundation for a simulation-to-hardware workflow.

ROS 2GazeboMoveItPython / PPO
Engineering notes +
  • Used ROS 2 Jazzy, Gazebo Harmonic, MoveIt, and RViz2 on Ubuntu for simulation and visualisation.
  • Explored PPO policies for pick-and-place tasks and end-effector positioning for metal 3D printing.
  • Studying pose, coordinate frames, inverse kinematics, Jacobians, trajectories, and feedback control; also exploring SLAM.
06 / Personal buildILLUSTRATION

In progress · Personal project

5-inch FPV quadcopter

Building an FPV quadcopter, from flight-controller and ESC integration to the camera, video transmitter, and goggles.

BetaflightFlySkyFPVBench integration
Engineering notes +
  • Integrating a Readytosky F4 V3S Plus flight controller with a separate ESC board.
  • Configured Betaflight and FlySky radio inputs.
  • Checked receiver response, motor operation, and receiver failsafe behaviour during bench setup.

The engineering toolkit

Across the whole system.

01

Mechanical design

FreeCAD, Autodesk Inventor, SOLIDWORKS, Blender, planetary gearing, motor actuation.

02

Electronics & embedded

KiCad, Arduino, TMC2209, Raspberry Pi Zero, Jetson Orin Nano, servos, steppers, brushless motors and ESCs.

03

Robotics & perception

OpenCV, YOLOv8; exploratory ROS 2 Jazzy, Gazebo Harmonic, MoveIt, RViz2, SLAM and PPO.

04

UAV systems

Manual aircraft controls, ArduPilot mission planning, Betaflight configuration, flight-controller and sensor integration.

Experience & approach

Hardware thinking.
Software depth.

Almost a decade across software and hardware development, with hands-on robotics and UAV project experience at Wicrypt Labs. My work culture is simple: point-blank focus.

More about me
Wicrypt Labs

RL & Robotics Engineer

Robotics and UAV development spanning aircraft controls, planetary gearing, PCB design, computer vision, and simulation.

A software foundation

Hammer Games · DevOps Engineer
Jul 2024 – Dec 2024

Loooty · Frontend Engineer
Mar 2022 – Jan 2023

The other side of my work

Good machines need
good software.

Full-stack applications, cloud infrastructure, and developer tooling. Explore the software behind my engineering foundation.

Explore software